Wonik Robotics Allegro Hand V5 Plus
In stock
- МАРКА:
- Wonik Robotics
- МОДЕЛ:
- Allegro Hand V5 Plus
- ЧАСТ #:
- Allegro Hand V5 Plus
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Wonik-Allegro-Hand-V5-Plus
Wonik Robotics Allegro Hand V5 Plus
Overview
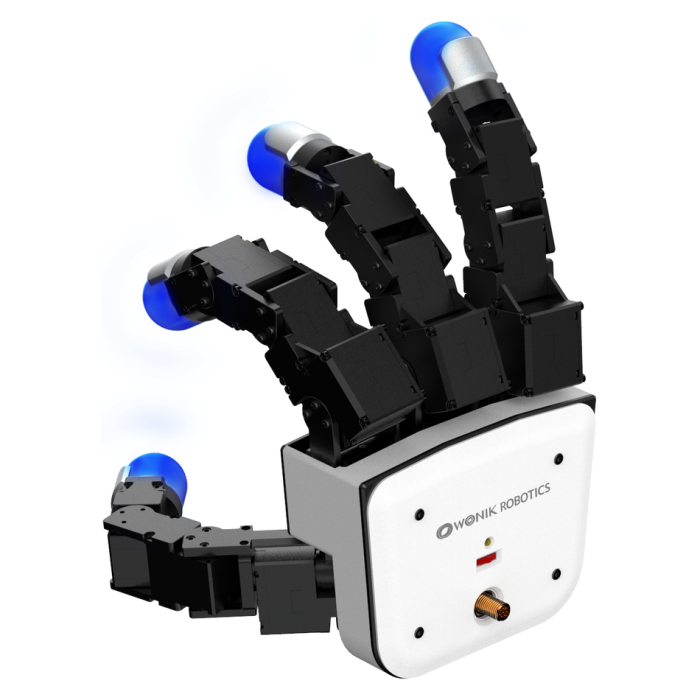
The Wonik Robotics Allegro Hand V5 Plus is a multi-fingered robotic hand developed for dexterous manipulation work in research and industrial settings. It provides sixteen active degrees of freedom distributed across four fingers, arranged as three fingers plus one thumb, with four joints per finger. Each joint is independently current-controlled, which allows fine-grained coordination of finger motion and is intended to support more precise control and stable grasping of objects with diverse shapes.
Watch the manufacturer product demonstration
According to the manufacturer, key components of the V5 Plus have been enhanced with the latest technology, and the hand is equipped with 360-degree omnidirectional pneumatic tactile sensors that detect pressure at each fingertip. The platform is presented alongside multiple ready-to-use grasping algorithms described as capable of handling a variety of object geometries, together with support for real-time control and online simulation.
Design and Mechanical Construction
The Allegro Hand V5 Plus uses a four-finger anthropomorphic layout in which three fingers oppose a single thumb. Every finger contains four actively driven joints, giving the complete hand sixteen active degrees of freedom. Actuation is provided by DC motors, and joint-level current control is used throughout, meaning each of the sixteen joints can be commanded individually rather than through coupled or underactuated linkages.
Two gear ratios are specified: 288.35:1 in general, and 576.7:1 for the second joint of each finger excluding the thumb. The torque figures follow the same pattern. Stall torque is listed as 0.92 Nm, rising to 1.84 Nm at the second joint of the non-thumb fingers, while nominal torque is 0.23 Nm and 0.46 Nm respectively. Joint resolution is specified at 0.088 degrees, a figure relevant to researchers who need repeatable fine positioning during manipulation experiments.
The complete hand weighs 1,024 grams. The manufacturer lists a payload of 15 kg, explicitly qualified as depending on the measurement method. This qualifier should be kept in mind when comparing the figure against application requirements, since payload values for robotic hands can vary considerably with grasp configuration and how the load is applied.
Fingertip Tactile Sensing
A defining feature of the V5 Plus is its fingertip sensing system. Each fingertip carries a 360-degree omnidirectional pressure-sensitive tactile sensor shaped like a finger. The sensor operates on an air-pressure measurement principle using a capacitive pressure sensor, and its stiffness is described as similar to a human finger. The manufacturer also notes that the sensor color changes based on tactile sensitivity. The manufacturer describes the omnidirectional fingertip sensors as enabling various types of research.
The documentation states that the hand is capable of flexibly manipulating objects ranging from rigid items to deformable soft materials. The sensor is described strictly as a pressure-detecting device; the published material does not equate its measurements with grasp force limits, so the pressure sensing capability should not be treated as a guaranteed force threshold for any particular task.
Fingertip Options
Wonik Robotics offers several fingertip variants, sold separately, so the tip can be matched to the application. Type A is the default standard attachment, with an internal structure supporting the external silicone surface to enable a firm grip. Type B places the supporting structure for the silicone surface externally and is described as suitable for delicate object gripping. Type C shortens the sensor and restricts measurement to the upper part of the sensor, allowing a strong grip. Type D adds a wide supporting structure on the back of the sensor, enabling a strong lateral grip.
Verified Specifications
| Specification | Value |
|---|---|
| Number of fingers | 3 fingers + 1 thumb = 4 |
| Degrees of freedom | 4 fingers x 4 = 16 (active) |
| Actuation type | DC motor |
| Gear ratio | 288.35:1 / 576.7:1 (second joint of the finger excluding the thumb) |
| Stall torque | 0.92 Nm / 1.84 Nm (second joint of the finger excluding the thumb) |
| Nominal torque | 0.23 Nm / 0.46 Nm (second joint of the finger excluding the thumb) |
| Payload | 15 kg (depending on the measurement method) |
| Weight | 1,024 g |
| Joint resolution | 0.088 deg |
| Communication type | CAN |
| Control frequency | 500 Hz (CAN) |
| Power requirement | 24.0 V / 5.0 A / 120 W |
Controls, Communication, and Software
The hand communicates over a CAN interface operating at 500 Hz, and the stated power requirement is 24.0 V at 5.0 A, corresponding to 120 W. All sixteen joints are current-controlled, and the manufacturer indicates support for real-time control as well as online simulation.
On the software side, the hand is supported by Allegro Hand UXD, described as a comprehensive hand control system delivered through a visualized application. Listed capabilities include real-time hand status monitoring, effortless hand pose generation, and versatile hand motion control via buttons. Multiple ready-to-use grasping algorithms are also referenced, aimed at handling a variety of object geometries without requiring every user to develop grasp planning entirely from scratch.
Research Context
The manufacturer describes the V5 Plus as a platform for dexterous manipulation research and industrial applications. The combination offered by the V5 Plus, namely sixteen independently current-controlled joints plus omnidirectional pressure sensing at every fingertip, is aimed at these areas. The manufacturer frames the platform as suitable for work with deformable and soft objects as well as rigid ones, which provides context for evaluating tactile-driven manipulation of these objects. Demonstration material referenced by the manufacturer includes pick-and-place examples with everyday objects such as an apple, a beverage can, and a dumbbell.
Integration Considerations
Before adopting the V5 Plus into a specific setup, several points are worth verifying against the intended application:
- Communication interface: confirm that the host control system can operate the hand over CAN at the stated 500 Hz rate and that cabling and bus topology fit the installation.
- Power supply: check that a 24.0 V supply capable of 5.0 A (120 W) is available where the hand will be mounted.
- Mounting and mass budget: verify that the carrying arm or fixture accommodates the 1,024 g hand weight in addition to any grasped load.
- Payload interpretation: evaluate the 15 kg payload figure, which depends on the measurement method, against the actual grasp configurations planned for the application.
- Fingertip selection: review the Type A through Type D fingertip options, which are sold separately, to determine which support structure best matches the objects to be handled.
- Software environment: confirm that the UXD visualized application and the provided grasping algorithms cover the required monitoring and motion-control workflows.
Frequently Asked Questions
How many fingers and degrees of freedom does the Allegro Hand V5 Plus have?
The V5 Plus has four fingers, arranged as three fingers plus one thumb. Each finger provides four actively driven joints, giving a total of sixteen active degrees of freedom, and every joint is independently current-controlled.
What kind of tactile sensing does the hand use?
Each fingertip carries a 360-degree omnidirectional pressure-sensitive tactile sensor shaped like a finger. It measures air pressure using a capacitive pressure sensor, has stiffness described as similar to a human finger, and its color changes based on tactile sensitivity.
Can the hand work with soft or deformable objects?
According to the manufacturer, the hand is capable of flexibly manipulating objects ranging from rigid items to deformable soft materials, supported by the omnidirectional fingertip pressure sensing and the independently controlled joints.
What fingertip options are available?
Four fingertip types are offered and sold separately. Type A is the standard firm-grip default, Type B suits delicate object gripping, Type C uses a shortened sensor with upper-area measurement for a strong grip, and Type D enables a strong lateral grip through a wide rear supporting structure.
How is the hand controlled and powered?
The hand communicates over CAN at 500 Hz and requires 24.0 V at 5.0 A, or 120 W. The Allegro Hand UXD visualized application provides real-time status monitoring, hand pose generation, and button-based motion control, and ready-to-use grasping algorithms are available.
How should the 15 kg payload figure be interpreted?
The manufacturer lists the payload as 15 kg depending on the measurement method. Because robotic hand payload varies with grasp configuration and loading direction, this figure should be evaluated against the specific grasps planned for an application rather than read as a universal limit.
Summary
The Wonik Robotics Allegro Hand V5 Plus is a four-finger, sixteen-degree-of-freedom robotic hand that combines independent current control at every joint with 360-degree omnidirectional pneumatic tactile sensing at each fingertip. With DC motor actuation, 0.088-degree joint resolution, CAN communication at 500 Hz, a 1,024 g weight, a 15 kg payload stated as depending on the measurement method, interchangeable fingertip types, and the UXD control application, it is positioned as a platform for dexterous manipulation research and industrial investigation across rigid and deformable objects.
Request a quotation to confirm configuration, pricing and availability. Catalog stock status is not confirmation of physical inventory or immediate shipment.