
Ti5 Robotics Intelligent Bionic Hand
In stock
- ZNAČKA:
- TI5 ROBOTICS
- MODEL:
- Intelligent Bionic Hand
- ORIGIN:
- Čína
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Ti5-Robotics-Intelligent-Bionic-Hand
Ti5 Robotics Intelligent Bionic Hand
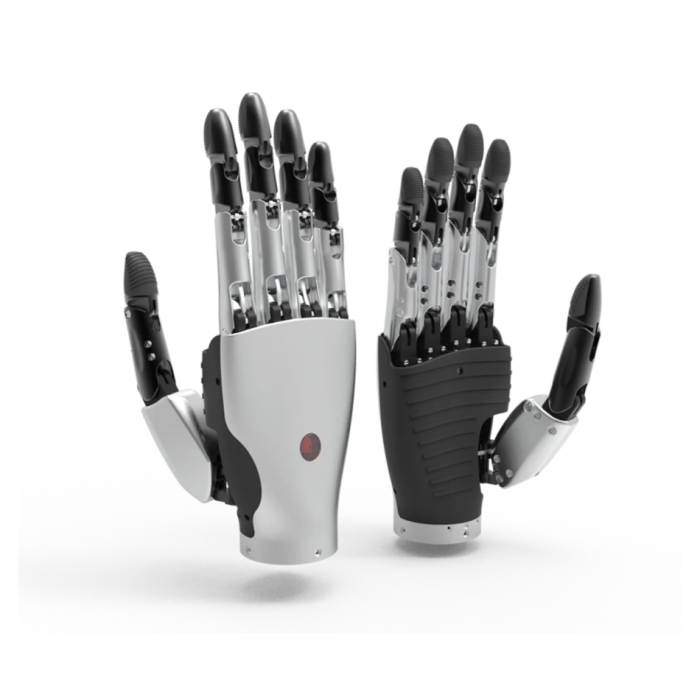
Ti5 Robotics Intelligent Bionic Hand is a compact, six-actuator robotic hand developed as a precision end-effector for humanoid robots, research platforms, and advanced manipulation projects. Built around the manufacturer's Cool Hand series architecture, the unit integrates bionics, mechatronics, materials science, biomedical engineering, and information technology in a single 480 g package. Each of the six internal actuator units drives a finger independently, while the thumb moves in two directions, allowing the hand to form a wide range of natural gestures and grips with motion that the manufacturer describes as nimble and intuitive, comparable to a real human hand.
Background
Dexterous robotic hands are among the most demanding components in modern robotics. They must combine high joint density, fine force control, and fast signal response inside a form factor close to that of a human hand. The Intelligent Bionic Hand addresses this by pairing a built-in intelligent flexible actuator with a torque control algorithm that enables precise force subdivision for delicate interaction, and by coordinating multiple joints simultaneously to achieve fine manipulation across complex tasks.
Design philosophy of the Cool Hand series
The Cool Hand series was conceived as a precision robotic component rather than a standalone product, and it is fully backed by independently developed intellectual property. Its proprietary motion-sensing control technology translates command inputs into coordinated finger motion, so the hand can replicate natural human gestures without requiring the integrator to program each joint in isolation. The emphasis on independent finger actuation, a two-direction thumb, and multi-joint coordinated control reflects a design goal of covering both power grips and precision pinches with one mechanism.
Force subdivision and signal response
Two engineering themes define the hand. The first is force subdivision: the torque control algorithm resolves commanded forces into fine increments, which matters when handling fragile, deformable, or irregular objects. The second is responsiveness: the manufacturer cites superior signal recognition and response speed as a significant competitive advantage in reaction time and reliability. Together these characteristics position the hand for tasks where both gentleness and repeatability are required, from laboratory manipulation studies to interactive demonstrations.
Technical Specifications
The following tables preserve the published configuration distinctions. Blank, malformed, or ambiguous source values are not confirmation of a capability; confirm the selected configuration during quotation.
Ti5 Robotics Intelligent Bionic Hand
| Dimension | Label | Value |
| Palm Width | A | 80 mm |
| Maximum Hand Width | B | 132 mm |
| Total Length (incl. fingers) | C | 205 mm |
| Finger Length | D | 97 mm |
| Thumb Base to Bottom of Palm | E | 132 mm |
| Parameter | Value |
| Fingertip Force | 10 N |
| Lateral Finger Force | 8 N |
| Palm Traction Force | 80 N |
| Closing Grip Force | 40 N |
| Thumb Force | 12 N |
| Parameter | Value |
| Degrees of Freedom | 6 |
| Weight | 480 g |
| Operating Voltage | 7.4 V |
| Static Current 0.1 A | 0.1 A |
| Maximum Current | 3 A |
How does the Intelligent Bionic Hand achieve human-like dexterity?
Dexterity in this design comes from the combination of six internal actuator units and coordinated control rather than from a large external drive system. Because each finger has its own actuator, the controller can move digits independently or in concert, and the two-direction thumb adds the opposition movement that most functional grasps depend on. The torque control algorithm then modulates how hard each finger presses, so the same hardware can pinch a light object at low force or close around a larger item using the full 40 N closing grip force and 80 N palm traction force. The documented 7.4 V operating voltage, 0.1 A static current, and 3 A maximum current indicate a power envelope that suits battery-powered humanoid platforms and bench setups alike.
Who is the Intelligent Bionic Hand for?
This component is aimed at robotics engineers and integrators building humanoid robots or manipulation testbeds, research groups studying grasping, teleoperation, and human-robot interaction, and educational institutions that need a realistic multi-finger hand for coursework and experimentation. It also suits commercial developers prototyping service or demonstration robots, and teams in the medical and rehabilitation research field exploring bionic manipulation concepts. Because it is supplied as a precision component, buyers should expect to handle electrical and software integration into their own platform.
What is the Intelligent Bionic Hand used for?
- Serving as a dexterous end-effector on humanoid robots, where independent finger actuation supports natural gestures and functional grasps.
- Scientific research and education, including grasp planning, manipulation benchmarking, and robotics teaching laboratories.
- Medical and rehabilitation engineering research, where bionic hand mechanisms are studied as part of broader investigation programs.
- Industrial production scenarios that call for delicate, force-controlled handling of small or sensitive items.
- Commercial scenarios such as interactive exhibits, reception robots, and demonstrations that benefit from lifelike hand motion.
- Teleoperation and motion-sensing experiments that exploit the proprietary control technology and fast signal recognition and response.
Pricing and Availability
The Intelligent Bionic Hand is sold as a precision robotic component, and pricing is provided on a quotation basis. Final cost depends on order quantity, configuration, and any accompanying integration requirements. To obtain current pricing, lead time, and availability for your project, submit a quote request through this listing and our team will respond with a tailored offer.
Frequently Asked Questions
How many degrees of freedom does the Intelligent Bionic Hand have?
The hand provides 6 degrees of freedom, driven by 6 internal actuator units. Each finger moves independently, and the thumb is capable of motion in two directions.
How much does the hand weigh and how large is it?
The unit weighs 480 g, with an 80 mm palm width, 132 mm maximum hand width, and a total length of 205 mm including the 97 mm fingers.
What forces can the hand generate?
Documented figures include 10 N fingertip force, 8 N lateral finger force, 12 N thumb force, 40 N closing grip force, and 80 N palm traction force.
What are the electrical requirements?
The hand operates at 7.4 V, drawing 0.1 A static current and up to 3 A maximum current, which makes it practical for battery-powered humanoid platforms.
Can each finger move independently?
Yes. Six internal actuator units give every finger independent motion, while multi-joint coordinated control lets the fingers work together for fine manipulation.
Is the Intelligent Bionic Hand suitable for research and education?
Yes. The manufacturer lists scientific research and education among its application areas, alongside industrial production, medical and rehabilitation research, and commercial scenarios.
Where can I buy the Ti5 Robotics Intelligent Bionic Hand and what does it cost?
You can purchase the Intelligent Bionic Hand directly through this listing. Pricing is quotation-based and varies with quantity and configuration, so please request a quote to receive current cost and delivery information.
Summary
The Ti5 Robotics Intelligent Bionic Hand packs six independently actuated fingers, a two-direction thumb, torque-controlled force subdivision, and fast signal response into a 480 g, 7.4 V component sized close to a human hand. For engineers, researchers, and educators evaluating a dexterous end-effector for humanoid or manipulation projects, this page is the starting point.


