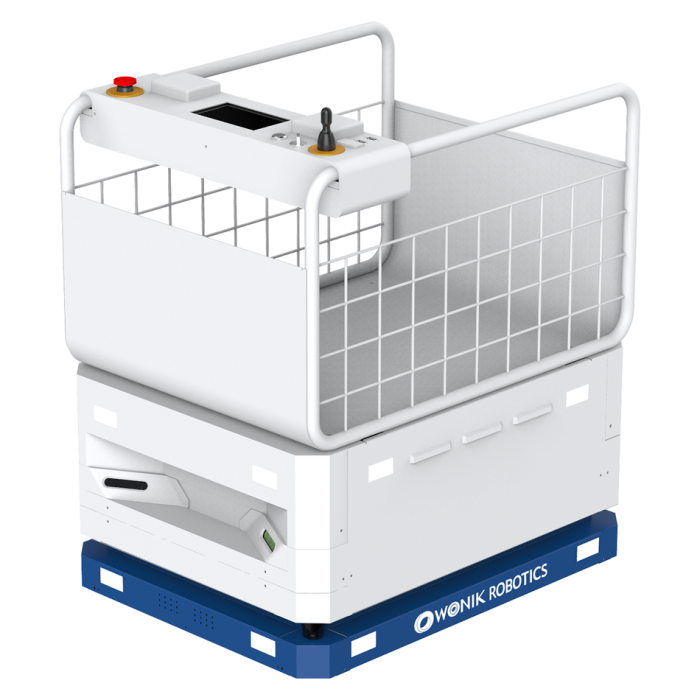
Wonik Robotics WR300CB
In stock
- BRANDA:
- Wonik Robotics
- MÚNLA:
- WR300CB
- CUID #:
- WR300CB
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Wonik-WR300CB
Wonik Robotics WR300CB
Overview
The Wonik Robotics WR300CB is an autonomous mobile robot (AMR) configured for manual and tray-based material handling, with equipment docking carried out through an LCD touch interface or a joystick. The platform is rated for a payload of 300 kg, reaches a maximum speed of 1.2 m/sec, and is listed with an operating time of 12 hours, positioning it for repetitive transport duties over extended shifts.
Design
The WR300CB measures 630 mm in width, 825 mm in length, and 940 mm in height. This footprint is compact relative to the 300 kg payload rating, which matters in facilities where aisle width and intersection clearance constrain the size of mobile equipment. The chassis uses a differential drive arrangement, in which two independently driven wheels control both propulsion and steering.
The drive wheels are made of urethane and measure 6 inches (15 cm), with two driving wheels fitted; the platform also carries four supporting sub-wheels. Loading on the WR300CB is handled manually or by tray, meaning goods are placed onto the robot by an operator or presented on trays rather than being transferred through powered conveyors on the robot itself. For aligning with equipment, the operator-facing docking method relies on the LCD touch screen or a joystick, giving staff direct control during docking procedures.
Specifications
| Item | Specification |
|---|---|
| Navigation Type | SLAM |
| Dimensions (W x L x H) | 630 x 825 x 940 mm |
| Payload | 300 kg |
| Driving System | Differential drive |
| Drive Wheels | Urethane, 6 in (15 cm), x 2 (plus 4 sub-wheels) |
| Loading Method | Manual / Tray |
| Equipment Docking Method | LCD touch or joystick |
| Stop Accuracy | ± 30 mm |
| Docking Accuracy (V marker) | ± 10 mm |
| Maximum Speed | 1.2 m/sec |
| Average Speed | About 0.7 m/sec |
| Operating Time | 12 h |
| Battery | Li-ion, DC24V / 50Ah |
| Charging Time | About 1 to 1.5 hours |
| Charging Method | Auto / Manual |
| Communication | Wi-Fi 2.4 GHz and 5 GHz; optional LTE/5G support |
Operational Considerations
Two distinct accuracy figures are published for the WR300CB, and they describe different situations. Stop accuracy of ±30 mm applies to how closely the robot halts relative to a target position during ordinary travel. Docking accuracy of ±10 mm applies specifically when the robot aligns using a V marker, a reference feature that allows tighter positioning. The tighter V-marker figure is relevant where the robot must line up with stations or fixtures, while the general stop accuracy governs routine waypoint stops. Planners should treat these as separate tolerances rather than a single positioning value.
Speed figures are similarly split: the 1.2 m/sec maximum represents the upper limit, while the stated average of about 0.7 m/sec better reflects sustained travel once acceleration, deceleration, cornering, and traffic interactions are considered. Throughput estimates for a route are therefore more realistic when based on the approximate average speed rather than the maximum.
Power comes from a lithium-ion battery rated at DC24V with 50Ah capacity, supporting the listed 12-hour operating time. Charging takes approximately 1 to 1.5 hours and can be performed automatically or manually. The combination of a long listed runtime and a comparatively short approximate charging window allows operations to schedule charging in gaps between tasks, though actual runtime in any deployment will depend on load, route profile, and duty cycle. For connectivity, the robot supports Wi-Fi on both 2.4 GHz and 5 GHz bands, and LTE/5G support is available as an option. Facilities with comprehensive wireless coverage can rely on Wi-Fi, while the optional cellular path may interest sites evaluating connectivity beyond local wireless networks.
Applications
With its 300 kg payload, manual/tray loading approach, and SLAM navigation, the WR300CB fits recurring point-to-point transport of totes, trays, and medium-weight goods inside mapped indoor environments. Typical scenarios include moving work-in-progress between production cells, carrying components from storage areas to assembly lines, and shuttling trays in warehouses or logistics areas. The compact dimensions suit facilities where corridor space is limited, and the differential drive layout helps in layouts with tight turns. Where the robot must align closely with equipment or stations, the V-marker docking capability with ±10 mm accuracy supports repeatable positioning, with the LCD touch or joystick docking method available for operator-directed alignment.
FAQ
What payload can the WR300CB carry?
The WR300CB is rated for a payload of 300 kg, loaded manually or by tray onto the platform.
How does the robot navigate?
The manufacturer lists SLAM as the navigation type for the WR300CB. This identifies the navigation approach separately from the published stopping and docking accuracy specifications.
What is the difference between stop accuracy and docking accuracy?
Stop accuracy of ±30 mm describes general halting precision at target positions, while docking accuracy of ±10 mm applies specifically when aligning with a V marker. They are separate tolerances for different operations.
How long does the WR300CB run and charge?
The listed operating time is 12 hours, and charging takes approximately 1 to 1.5 hours. Charging can be performed automatically or manually.
What connectivity options are available?
The robot supports Wi-Fi on 2.4 GHz and 5 GHz bands. LTE/5G support is optional rather than standard.
How is docking with equipment performed?
The listed equipment docking method is operator-facing, using the LCD touch interface or a joystick to carry out docking procedures.
Summary
The Wonik Robotics WR300CB is a compact differential-drive AMR rated for 300 kg payloads, combining SLAM navigation, manual/tray loading, and LCD touch or joystick docking. Its published figures include 1.2 m/sec maximum speed with an average of about 0.7 m/sec, ±30 mm stop accuracy, ±10 mm V-marker docking accuracy, a 12-hour operating time from a DC24V/50Ah lithium-ion battery, charging in approximately 1 to 1.5 hours by automatic or manual methods, and dual-band Wi-Fi with optional LTE/5G. These characteristics position it for repetitive indoor transport tasks in mapped facilities where footprint, positioning tolerance, and shift-length runtime are the deciding factors.
Request a quotation to confirm configuration, pricing and availability. Catalog stock status is not confirmation of physical inventory or immediate shipment.