
Xynova Prima 1
In stock
- ZNAČKA:
- XYNOVA
- MODEL:
- Prima 1
- ORIGIN:
- Čína
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Xynova-Prima-1
Xynova Prima 1
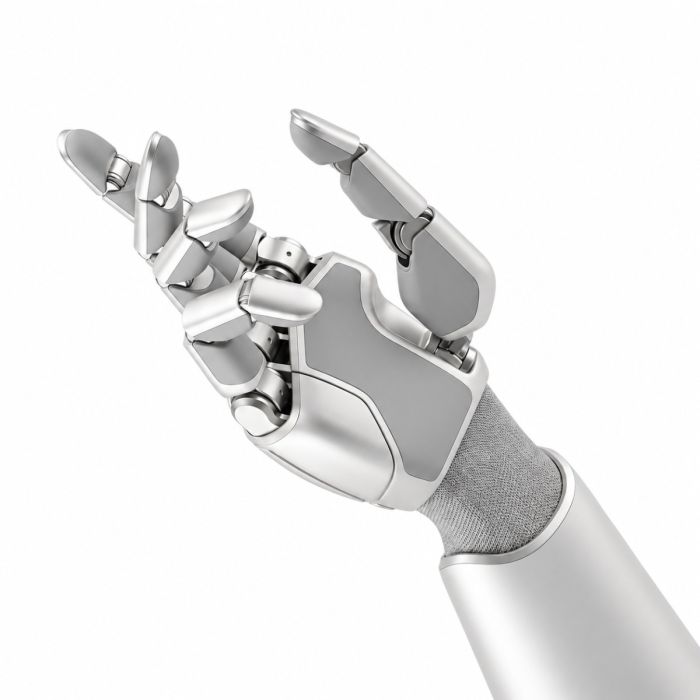
Most robot hands hide what they feel. Gears, tendons and reducers soak up friction and backlash, so the force a controller reads is never quite the force the fingers apply. For anyone training manipulation models, that gap becomes noise in the data. The Xynova Prima 1 removes it. Every one of its 22 degrees of freedom is driven directly, with zero backlash, so the hand behaves as a transparent instrument rather than a black box. The result is a research grade platform that is strong enough for real tasks yet precise enough to measure them, built for teams who need to know exactly how a grasp happened, not just whether it worked.

Xynova is a Hangzhou, China based developer that focuses exclusively on dexterous hands and the drive hardware behind them. The company runs two hand lines in parallel: the Flex series, which uses hybrid tendon and direct drive actuation for durable deployment, and the Prima series, which uses pure direct drive for research and algorithm development.
The Prima 1 was introduced in August 2026 at the World Robot Conference in Beijing. Xynova positions it as the platform for experimentation, data collection and model training, while the Flex 2 serves production environments.
Key Features
Strength in a Human Sized Hand
The Prima 1 follows a 1:1 biomimetic human hand design measuring 190 mm. It delivers 15 N of fingertip force and supports a lifting payload of up to 20 kg, covering the full range of everyday manipulation tasks.
Force Transparency
Because there is no gear train or tendon between motor and joint, force signals travel without distortion. Xynova specifies force control accuracy of 0.5 N and repeatability of 0.5 mm, with native support for hybrid force and position control.
Speed and Responsiveness
A 1 kHz response bandwidth gives controllers millisecond level authority over each finger. A single open and close cycle takes just 0.08 seconds.
Visuo-Tactile Sensing
All five fingers carry visuo-tactile sensors that combine visual and tactile feedback to capture subtle contact changes at the fingertips. The output is dense, high dimensional data well suited to learning based control.
Safe Interaction
A minimum back drive torque of just 0.04 Nm means the fingers yield easily to external force. That compliance protects people, objects and the hand itself during contact rich work and human guided teleoperation.
Xynova Prima 1 Specifications
| Specification | Xynova Prima 1 |
|---|---|
| Drive type | Fully direct drive, zero backlash |
| Degrees of freedom | 22 |
| Hand size | 190 mm, 1:1 biomimetic |
| Fingertip force | 15 N |
| Lifting payload | Up to 20 kg |
| Force control accuracy | 0.5 N |
| Repeatability | 0.5 mm |
| Open/close cycle | 0.08 s |
| Response bandwidth | 1 kHz |
| Minimum back drive torque | 0.04 Nm |
| Sensing | Five finger visuo-tactile |
| Control | Hybrid force and position control |
Prima 1 vs Flex 2
| Feature | Xynova Prima 1 | Xynova Flex 2 |
|---|---|---|
| Drive type | Fully direct drive | Hybrid tendon plus direct drive |
| Degrees of freedom | 22 | 23 |
| Load | Up to 20 kg lifting payload | 12 kg grasp, 4 kg rated continuous |
| Repeatability | 0.5 mm | ±0.1 mm |
| Primary focus | Research, data collection, model training | Industrial and service deployment |
Applications
- Embodied AI research: collect clean force and tactile datasets for manipulation policy training.
- Teleoperation: low back drive torque and fast response suit human guided data capture.
- Humanoid robot development: mount the Prima 1 on a humanoid or robot arm to prototype dexterous behaviors.
- Precision assembly studies: hybrid force and position control supports contact rich tasks such as insertion and fine part handling.
- Long horizon motion research: Xynova has demonstrated the Prima 1 painting traditional ink wash landscapes on a robot, showing stable, controlled motion over extended sequences.
Who Should Buy the Xynova Prima 1?
The Prima 1 is the right choice for university labs, corporate AI research groups and robotics startups whose core work is learning, measuring or modeling manipulation. If your success depends on trustworthy force data more than on running a hand all day on a production line, this is the Xynova hand to buy.
Which Should You Buy?
| If you need... | Choose |
|---|---|
| Transparent force data for AI training | Xynova Prima 1 |
| Teleoperation and dataset collection | Xynova Prima 1 |
| Higher lifting payload | Xynova Prima 1 |
| Durable hand for daily production work | Xynova Flex 2 |
| Finer positional repeatability | Xynova Flex 2 |
Before You Buy
- Confirm mounting: check the wrist interface of your arm or humanoid and ask for the mechanical drawing before ordering.
- Plan your software stack: confirm the control interface, SDK and data formats your team will use for teleoperation and training.
- Check power and cabling: request the electrical specifications so you can plan supply and routing through the wrist.
- Request full datasheets: weight and continuous duty figures are not yet listed on the manufacturer page, so confirm them for your application.
- Plan for pairs: bimanual research usually needs a left and right hand, so include both in your quote.
Pricing and Availability
The Xynova Prima 1 is sold by quote. Add it to your quote from this page and our team will reply with current price, cost details and lead time for your configuration and quantity. The hand is covered by a 12 month warranty, and availability depends on production allocation.
Frequently Asked Questions
What is the Xynova Prima 1?
The Xynova Prima 1 is a fully direct drive dexterous robot hand with 22 degrees of freedom, five finger visuo-tactile sensing and a human sized 190 mm design, built for research and AI model training.
How strong is the Xynova Prima 1?
The Prima 1 delivers 15 N of fingertip force and can lift a payload of up to 20 kg, according to the manufacturer.
Why does direct drive matter in a robot hand?
Direct drive removes gears and tendons between motor and joint, eliminating backlash and friction losses. Force readings stay accurate, which makes training data cleaner and control more predictable.
How fast is the Xynova Prima 1?
The hand completes a full open and close cycle in 0.08 seconds and has a 1 kHz response bandwidth.
What is the difference between the Prima 1 and Flex 2?
The Prima 1 is fully direct drive and aimed at research and data collection. The Flex 2 uses hybrid tendon and direct drive actuation and is designed for durable industrial and service deployment.
How much does the Xynova Prima 1 cost?
The Prima 1 is quote only. Request a quote on this page to receive current price and cost details for your order.
Where can I buy the Xynova Prima 1?
You can buy the Xynova Prima 1 right here on this page. Add it to your quote and our team will follow up with pricing and availability.
Summary
The Xynova Prima 1 turns the robot hand into a measuring instrument. Full direct drive, 22 degrees of freedom, five finger visuo-tactile sensing and 0.5 N force control accuracy give research teams the transparent data they need to train and test dexterous manipulation. If you are ready to buy a research grade hand for embodied AI work, request a quote on this page for current price and availability.


