
BrainCo Revo 1 Intelligent Dexterous Bionic Hand
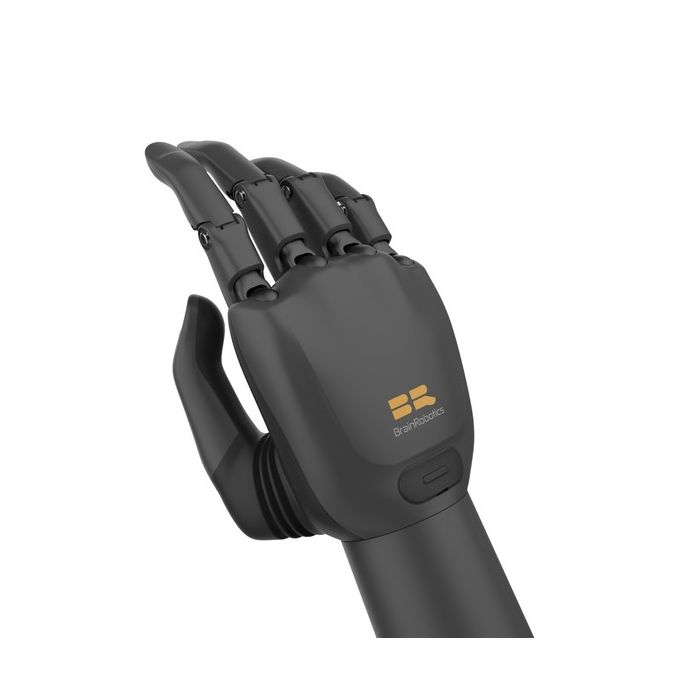
The BrainCo Revo 1 Intelligent Dexterous Bionic Hand is a robotic dexterous hand platform from BrainCo, a brain-computer-interface and human-machine-interface company that publicly lists “BrainCo Bionic Dexterous Hand Revo1” among its product lines on its official website. BrainCo positions itself as a company working across bionic hands, bionic knees, neurotechnology, and AI-oriented robotics solutions.
In stock
- BRANDA:
- BRAINCO
- CUID #:
- Intelligent Dexterous Bionic Hand
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Dexterous-Bionic-Hand
BrainCo Revo 1 Intelligent Dexterous Bionic Hand
Six active joints, ten degrees of freedom: the arithmetic behind the BrainCo Revo 1 Intelligent Dexterous Bionic Hand is the whole argument for it. A hand that drives only some of its movements and lets the rest follow passively can close around an object rather than clamp it. For teams that need to experiment with grasping rather than simply holding, that is the interesting design choice.
Robots Europa, based in Dublin, supplies the Revo 1 to customers across the EU and the DACH region. Robots Europa prepares the quotation, arranges delivery and provides support for the configuration you select, so the hand, the variant and the follow-up questions are handled by one seller.
Background
The BRAINCO brand and the Revo 1 range
BRAINCO is the brand behind this hand. The Revo 1 is offered in several versions, and the model codes identify them. Revo 1 Basic is sold as MRL1 (left) and MRR1 (right). Revo 1 Basic Touch is sold as MTL1 (left) and MTR1 (right). Revo 1 Advanced is sold as MEL2 (left) and MER2 (right). The public hardware variants are Revo 1 Basic and Revo 1 Advanced, and tactile sensing depends on the SKU. For that reason the code of the version you want should always travel with your enquiry.
Robots Europa lists the Revo 1 within a wider range of BrainCo hands. Newer hands from the same brand, such as the BrainCo Revo 2 Basic Right Dexterous Bionic Hand (XRR), have their own pages, and their figures should be read there rather than carried over to the Revo 1.
How the hand is built and controlled
The Revo 1 is a biomimetic dexterous hand, which means its layout follows the logic of a human hand. The thumb has two active degrees of freedom: abduction/adduction and flexion/extension. Each of the other four fingers has one active degree of freedom for flexion/extension and one passive degree of freedom for flexion/extension. Together these give the hand its 6 active joints and 10 degrees of freedom.
On the software side, the hand is supported by a C SDK and a Python SDK, so it can be driven from either a low-level control stack or a quick research script. Each hand carries a device ID. The default is 1 and it can be changed within the range 1 to 254, which matters when more than one hand shares a communication line. The Basic and Advanced variants have model-specific interfaces and tactile options, so integration notes should be read against the version you order.
Two behaviours are worth knowing before the hand reaches your bench. After power-on, the hand runs a position calibration sweep, and all fingers move during it, so the workspace around the hand must be clear at start-up. The hand also has a turbo mode: after a finger stalls against an object, it pauses for the configured stall duration and then continues gripping at 500 ms intervals.
Technical Specifications
| Specification | Value |
|---|---|
| Active joints | 6 |
| Degrees of freedom | 10 |
| Thumb | Two active degrees of freedom (abduction/adduction, flexion/extension) |
| Other four fingers | Each one active and one passive degree of freedom (flexion/extension) |
| Maximum hand load | 30 kg |
| Five-finger grip force | 50 N |
| Supply voltage (Revo 1 Basic) | 9.5 ~ 28 V |
| Turbo mode re-grip interval | 500 ms after the configured stall duration |
| Default device ID | 1 (adjustable from 1 to 254) |
| Software development kits | C SDK and Python SDK |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the weight, the dimensions, the IP rating, the contents of the box or the operating noise; these are confirmed at quotation.
What makes the Revo 1 different from a simple gripper?
A conventional two-finger gripper has one job: open and close. It is fast to integrate and robust, but it offers little to a team that wants to study how a hand adapts to an object. The Revo 1 starts from the opposite assumption. Its thumb moves in two directions, so it can be positioned against the fingers rather than simply opposed in a line. Its four fingers each combine a driven joint with a passive one, so the finger shape can follow the object it meets.
The figures show what that arrangement is intended to deliver. A maximum hand load of 30 kg and a five-finger grip force of 50 N describe a hand that is meant to do real holding work, not only to demonstrate finger motion. The turbo mode adds a further control idea: when a finger stalls against an object, the hand does not simply stop, it waits for the configured stall duration and then keeps gripping at 500 ms intervals. For a developer, that is a behaviour to be tuned for the task, whether the object is rigid or yielding.
The calibration sweep at power-on is the other practical difference. A hand that finds its own reference positions is easier to bring into a repeatable routine than one that must be zeroed by hand. The price of that convenience is that all fingers move at start-up, which should be planned into any cell layout or safety procedure.
Which Revo 1 version should you choose?
The choice follows from the sensing you need and the side of the robot on which the hand will sit. Revo 1 Basic (MRL1 and MRR1) is the starting point for work that is driven by position and force settings alone. Revo 1 Basic Touch (MTL1 and MTR1) adds tactile sensing, which suits experiments where contact information feeds back into the controller. Revo 1 Advanced (MEL2 and MER2) is the other public hardware variant, with its own interfaces and tactile options. The L and R in the codes mark the left and right hands.
The supply voltage of 9.5 ~ 28 V is published for the Revo 1 Basic. If you intend to order another version, ask for its electrical figures when you request the quotation, so that the power supply in your design is matched to the hand you receive.
Who is the BrainCo Revo 1 for?
Research laboratories are the most natural buyers. A hand with 10 degrees of freedom and two SDKs lets a group test grasp planning, teleoperation or learning-based control without first building a hand. The Python SDK in particular suits teams that prototype quickly, while the C SDK suits those who need to embed control in an existing system.
Integrators and developers of robot cells form the second group. They need to know how the hand starts, how it is addressed on a shared line and how it behaves when a finger meets resistance. The device ID range, the calibration sweep and the turbo mode are all answers to those questions. Educators and university courses form the third segment: a hand with a visible, anatomical layout is a clear teaching tool for manipulation and control.
Buyers who need tactile feedback should look at the Basic Touch version, and those who want the other public variant should ask about the Advanced one. Those who want to compare generations can browse the full BrainCo Revo 1 category, or look at the Revo 2 and Revo 3 pages, for instance the BrainCo Revo 3-21 Basic Robot Hand, each of which carries its own figures.
What is the BrainCo Revo 1 used for?
- Manipulation research. Study how a multi-finger hand forms a grasp, using the SDKs to command each active joint.
- Robot-cell integration. Fit a dexterous end-effector to an arm for tasks that a two-finger gripper handles poorly.
- Teaching and demonstration. Show students how thumb opposition and finger flexion combine into a working grasp.
- Control-software development. Tune behaviours such as the turbo mode and stall duration against real objects.
- Tactile experiments. With a touch-equipped SKU, explore how contact information can feed back into grasp control.
- Multi-device setups. Use the adjustable device ID to address several hands from one control system.
Pricing and Availability
Robots Europa does not publish prices on this page. Send a request for a quotation, naming the version and the side you need, and you will receive an offer for that configuration. Delivery, customs and support are arranged with the quotation. The current ordering route for each version is available on this page.
Frequently Asked Questions
How many joints and degrees of freedom does the Revo 1 have?
The Revo 1 has 6 active joints and 10 degrees of freedom. The thumb has two active degrees of freedom, and each of the other four fingers has one active and one passive degree of freedom.
What load and grip force can it manage?
The maximum hand load is 30 kg and the five-finger grip force is 50 N.
What does the hand do when it is switched on?
It runs a position calibration sweep automatically, and all fingers move during it. Keep the area around the hand clear at power-up.
What is turbo mode?
When a finger stalls against an object, it pauses for the configured stall duration and then continues gripping at 500 ms intervals.
Which software can control it?
A C SDK and a Python SDK are available. The default device ID is 1 and it can be set anywhere from 1 to 254.
Which versions exist, and does every version have tactile sensing?
The versions are Revo 1 Basic (MRL1/MRR1), Revo 1 Basic Touch (MTL1/MTR1) and Revo 1 Advanced (MEL2/MER2). Tactile sensing depends on the SKU, so state the code you need when you enquire.
Where can I buy the BrainCo Revo 1 and what does it cost?
You can buy it from Robots Europa in Dublin, which supplies the EU and the DACH region. The cost depends on the version and configuration, so request a quotation through this page.
Summary
The Revo 1 rewards the buyer who counts: 6 active joints, 10 degrees of freedom, a two-axis thumb and fingers that pair a driven joint with a passive one. Add a 30 kg maximum hand load, a 50 N five-finger grip force, a self-calibrating start-up, turbo mode and two SDKs, and the result is a hand built to be programmed and studied. Choose the version by its model code, confirm the unpublished details at quotation, and let Robots Europa arrange the rest. When you are ready to specify your hand, this page is the starting point.


