
Dexforce W1 Pro General Purpose Embodied Intelligence Wheeled Humanoid Robot (W1 Pro)
In stock
- BRAND:
- DEXFORCE
- PART #:
- W1 Pro
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- DexForce-W1-Pro
Dexforce W1 Pro General Purpose Embodied Intelligence Wheeled Humanoid Robot (W1 Pro)
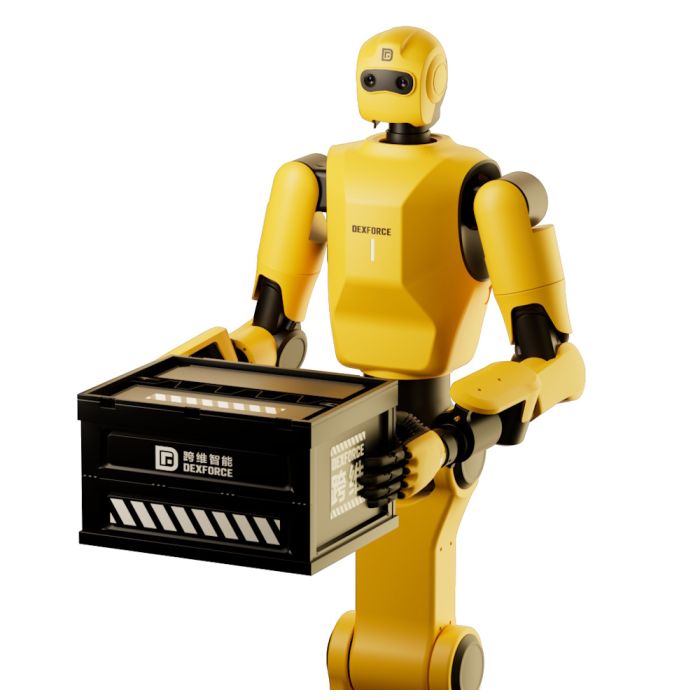
Training a robot policy in simulation is the easier half of the problem. The harder half is finding a physical body precise, sensitive and steady enough to carry those learned skills into a real room without losing them in translation. The Dexforce W1 Pro General Purpose Embodied Intelligence Wheeled Humanoid Robot (W1 Pro) is built for that second half. It pairs a humanlike upper body with a wheeled base: two seven-joint arms, a moving neck and torso, and stereo eyes in the head. The whole machine connects to a Sim2Real pipeline that generates and trains on data before a single real object is handled. This is a platform less suited to trade-show demonstrations than to teams who want to close the loop between virtual training and physical work.
Robots Europa, based in Dublin, supplies the Dexforce W1 Pro to research institutions, system integrators and businesses across the European Union and the DACH region. Robots Europa prepares each quotation around the configuration you specify, arranges delivery to your site and provides after-sales support. You deal with one partner from the first enquiry to commissioning.
Background
DEXFORCE and the general-purpose idea
DEXFORCE built the W1 Pro as a general-purpose embodied intelligence robot. The machine is not designed around a single task; it is meant to be reconfigured and retrained as requirements change. That philosophy shows in the optional components available. These include a dexterous hand or a two-finger gripper, a humanoid or an industrial-style robotic arm, a differential or an omnidirectional mobile chassis, and a dual-PC configuration. The range also includes a sibling, the Dexforce W1 Core General Purpose Embodied Intelligence Wheeled Humanoid Robot, so buyers can choose the level of platform that matches their programme.
Sim2Real and the EmbodiChain pipeline
The software side of the W1 Pro is a Sim2Real VLA pipeline. VLA stands for vision-language-action, a class of models that map what a robot sees and is told to the movements it makes. The pipeline offers massive online data generation and training via EmbodiChain. In practice, this approach lets a team produce large volumes of synthetic training data in simulation rather than recording every demonstration by hand. They then transfer the resulting skills to the physical robot. The hardware is built to make that transfer workable. Joints are controlled in real time at high frequency, force is measured finely, and the actuators communicate over an industrial-grade network.
Technical Specifications
| Specification | Value |
|---|---|
| Dimensions (L×W×H) | 682mm*550mm*1636mm |
| Weight | 110kg |
| Full-body DOF, differential chassis | 34 |
| Full-body DOF, omnidirectional chassis | 40 DOF for the full body |
| Single arm DOF | 7 DOF (Shoulder: 3; elbow: 1; wrist: 3) |
| Max payload (single arm) | 10kg |
| Arm repeatability (without hand) | ±0.5 mm |
| Torso DOF | Neck: 2 DOF, Waist: 2 DOF, Leg: 2 DOF |
| Chassis DOF | 8 DOF for omnidirectional chassis, 2 DOF for differential chassis |
| Movement mode | Differential (Optional: Omnidirectional) |
| Straight-line speed | Max 1.5m/s, Rated 1.2m/s |
| Navigation method | Laser SLAM |
| Navigation LiDAR | 2 pcs (Diagonally mounted on chassis) |
| Head vision | 6cm Baseline Humanoid Binocular Vision + Large-Model Binocular Algorithm |
| Battery life | ≥8H Continuous Power Supply (Wired) |
| Battery capacity | 40 Ah; Optional: LiFePO4 Battery (40 Ah) |
| Computing power | Total system computing power ≥ 300 TOPS |
| Control frequency | 1000Hz real-time control of full-body joints |
| Force control precision | 0.1N |
| Industrial network | EtherCAT industrial ring network |
| Software engine | Sim2Real VLA Pipeline: Massive data online gen & training (via EmbodiChain) |
Specifications are as published by the manufacturer and are confirmed against the datasheet at quotation.
The manufacturer has not published the IP rating, charging time, operating temperature, package contents, Wi-Fi and Bluetooth support or noise level; Robots Europa confirms these at quotation.
Why choose a wheeled humanoid rather than a legged one?
A legged humanoid devotes much of its control effort and energy to balance. That is valuable on stairs or rough ground, but it is a cost on the flat floors of a laboratory, shop or factory. The W1 Pro gives that problem to a wheeled chassis and spends its engineering on the upper body. Each arm has seven degrees of freedom and carries up to 10kg. Without a hand fitted, it repeats a position to ±0.5 mm. The torso adds a neck, a waist and a leg section with two degrees of freedom each, so the robot can lean, bend and look towards its work much as a person standing at a bench would.
A wheeled base also suits data collection and long trials. It parks stably while the arms work, and it navigates by Laser SLAM using two LiDAR units mounted diagonally on the chassis. Its rated straight-line speed is 1.2m/s, with a maximum of 1.5m/s. The control architecture is just as relevant to research teams. Full-body joints run at 1000Hz real-time control over an EtherCAT industrial ring network, and force control has a precision of 0.1N. Policies trained in simulation depend on that kind of fine, predictable actuation to behave on the real machine as they did in the virtual one.
Differential or omnidirectional chassis: which should you specify?
The W1 Pro is offered with a differential chassis as standard, with an omnidirectional chassis as an option, and the choice changes the robot's degree-of-freedom count. With the differential chassis, the chassis contributes 2 DOF and the full body reaches 34 DOF. With the omnidirectional chassis, the chassis contributes 8 DOF and the full body reaches 40 DOF. A differential base turns and drives much like a wheelchair, which is simple and well suited to open aisles and corridors. An omnidirectional base can also move sideways and reposition without turning. This matters in tight cells, alongside shelving or wherever the arms must stay aligned with a work surface while the body shifts. Robots Europa can discuss your floor layout and tasks before you settle the configuration.
Who is the Dexforce W1 Pro for?
The clearest fit is a research group working on embodied AI: university laboratories, corporate research centres and AI teams developing vision-language-action models. For them, the Sim2Real pipeline, the total system computing power of ≥ 300 TOPS and the dual-PC option make the robot a testbed as much as a tool. A second group is system integrators building pilots in service and light industrial settings. These teams value a humanoid form that can work at existing benches and shelves without the site being redesigned around it. Organisations exploring automation in shops and stores will find related platforms in our Retail Robots category. Buyers comparing the wider field of mobile manipulators can browse our Wheeled Humanoids range.
Teams who do not need the full Pro specification may also wish to consider the Dexforce W1 Core. Robots Europa can set the two versions side by side at quotation so the choice rests on your actual requirements.
What is the Dexforce W1 Pro used for?
- Embodied AI research: a physical platform for developing and validating vision-language-action policies.
- Sim2Real data generation: producing synthetic training data at scale and testing how well skills transfer to hardware.
- Laboratory automation: handling samples, tools and containers at benches built for human workers.
- Retail and service pilots: trialling shelf replenishment, item retrieval and customer-facing tasks on shop floors.
- Light industrial handling: pick-and-place, kitting and machine tending where a flexible, reconfigurable cell is needed.
- Teaching and training: giving students and engineers hands-on experience of whole-body robot control and AI deployment.
Pricing and Availability
Every W1 Pro is configured to order, with choices of end effector, arm type, chassis and computing setup, so Robots Europa prices it by quotation rather than from a fixed list. Tell us which components you need, where the robot will be deployed and what you intend it to do, and we will prepare a quotation for that configuration. Delivery, customs and support are arranged with the quotation. To begin, use the quotation request available on this page.
Frequently Asked Questions
How many degrees of freedom does the W1 Pro have?
With the differential chassis, the full body has 34 DOF. With the optional omnidirectional chassis, it has 40 DOF. Each arm has 7 DOF.
How much can each arm lift?
Each arm has a maximum payload of 10kg. Arm repeatability without a hand fitted is ±0.5 mm.
How does the robot navigate?
The W1 Pro uses Laser SLAM navigation with two LiDAR units mounted diagonally on the chassis. Its head carries a 6cm baseline humanoid binocular vision system with a large-model binocular algorithm.
Which end effectors are available?
A dexterous hand or a two-finger gripper is available as an option. A humanoid or industrial-style robotic arm can also be specified.
What does the software pipeline do?
The Sim2Real VLA pipeline provides massive online data generation and training via EmbodiChain. Skills can be developed in simulation and then transferred to the physical robot.
How much computing power does the W1 Pro carry?
Total system computing power is ≥ 300 TOPS. A dual-PC configuration is available as an option for teams that need to separate workloads.
Where can I buy the Dexforce W1 Pro and what does it cost?
Robots Europa supplies the Dexforce W1 Pro across the EU and the DACH region. Because each robot is configured to order, the price is given in a quotation prepared for your configuration, which you can request on this page.
Summary
The W1 Pro answers the question that simulation alone cannot: whether a skill learned in software survives contact with the real world. Its wheeled base takes the burden of balance away from the upper body. Its seven-joint arms, articulated torso and binocular head give policies a humanlike body to act through. High-frequency joint control, fine force sensing and an EtherCAT network keep that body predictable enough for trained models to trust. Paired with the Sim2Real pipeline, the robot becomes a working bridge between virtual training and physical tasks. For research groups, integrators and pilot projects in Europe ready to cross that bridge with Robots Europa, this page is the starting point.


